Quick Start: IF800 Tomcat
Hardware requirements
- IF800 Tomcat drone
- SkyHub V3 (with mounting kit)
- SkyHub cable for Pixhawk Payload Bus
- Altimeter (laser or radar) with a mounting bracket
Software requirements for the Windows PC
- UgCS v5.14.0 or higher (referred to below as UgCS)
- UgCS Custom Payload Monitor v4.4.0 or higher (referred to below as UgCS-CPM)
Software requirements for the Remote Controller
- Inspired Ground Control v1.5.4 or higher
Network requirements
- Any Wi-Fi/hotspot to connect the Remote Controller and the Windows PC within a single network.
UgCS desktop download and setup process
- Download the installation package.
- Run the setup file.
- Read and acknowledge the license agreement.
- In the component selection tab, you can select additional autopilot support (if necessary).
- Installation complete.
UgCS Custom Payload Monitor download and setup process
- Download the latest available CPM version.
- Run the setup file.
- Select the SkyHub license file for the SkyHub you will be using.

- Read and acknowledge the license agreement.
- Installation complete.
Note
If you do not have a license file or need a new one, please reach out to us at support@ugcs.com and provide your SkyHub serial number.
SkyHub installation on the drone
Caution
Power off the system when connecting cables. To avoid short-circuiting or causing potentially harmful power fluctuations, it is recommended to power off the entire system before performing any cable plug-in or unplugging. Some of the payload sensors used are extremely sensitive to power changes and may be damaged.
Components
SkyHub assembly kit contains the following components:
- SkyHub onboard computer
- SkyHub cable for Pixhawk Payload Bus
- Altimeter mounting bracket
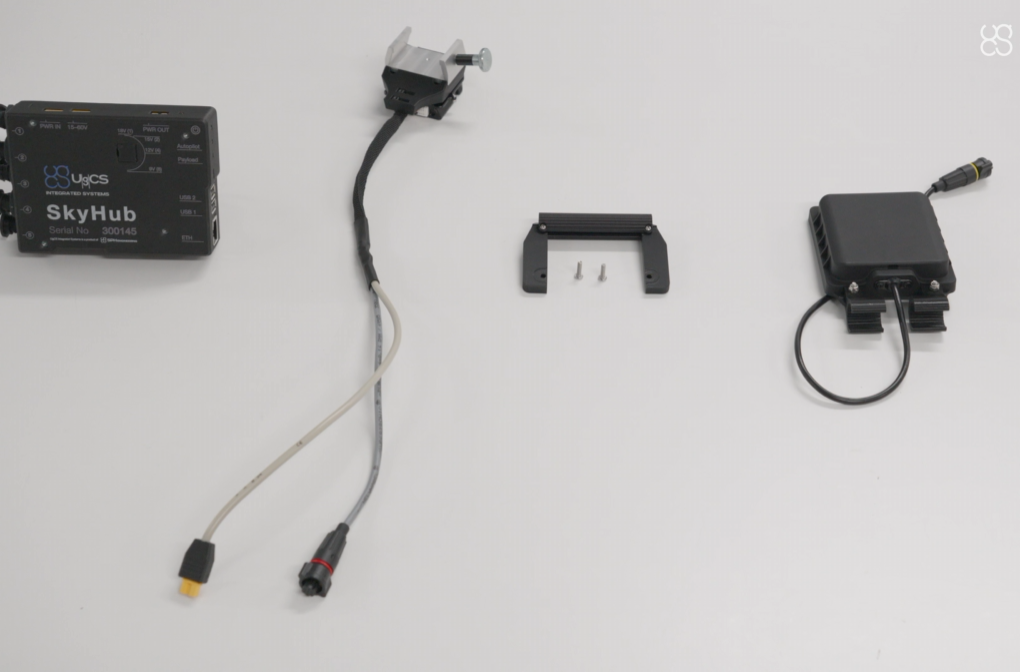
Physical assembly
Danger
It is advised to install the altimeter bracket first; otherwise, access to the mounting points on the drone might be obscured later on during the assembly
- Attach the altimeter mounting bracket to the body of the drone below.
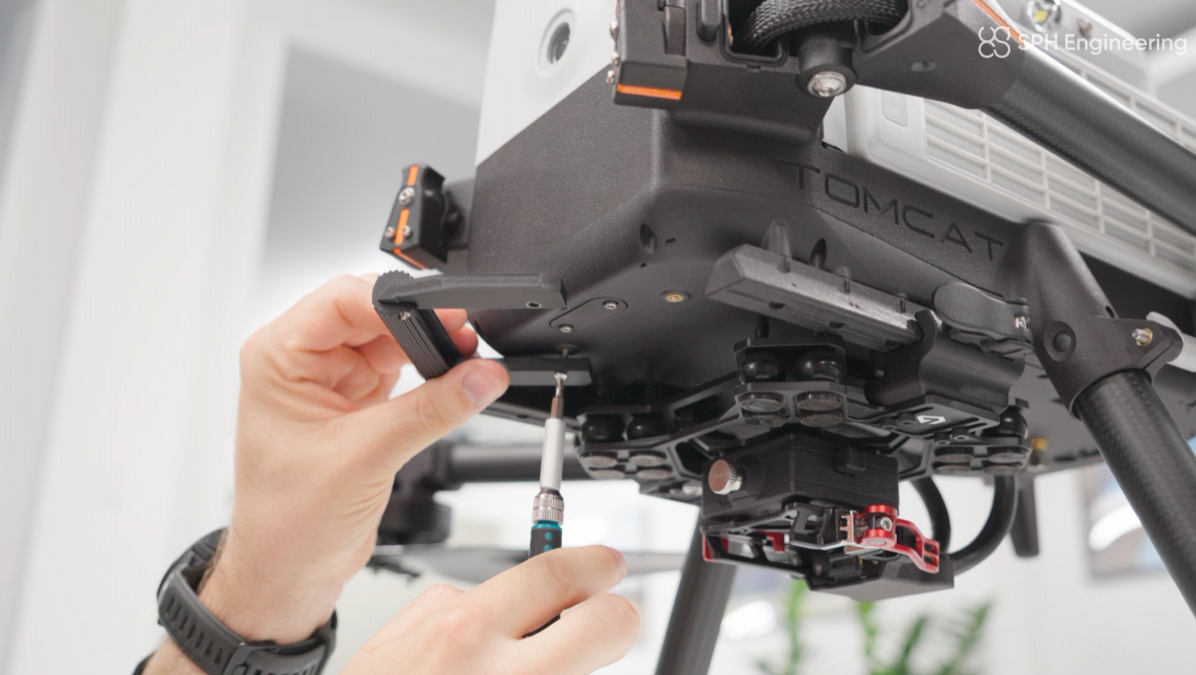
Note
If the built in gimbal is in the way of the mounting points, you can slide it all the way back.
- Attach the dovetail cable to the gimbal.
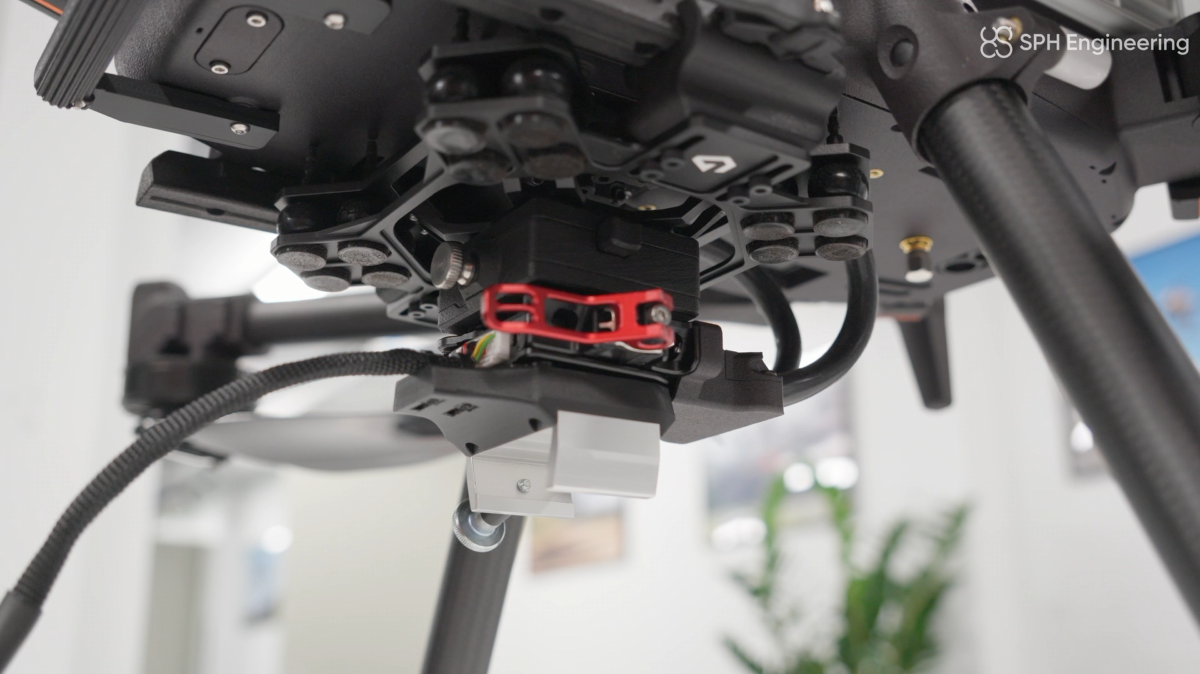
- Attach the SkyHub to the leg of the drone.
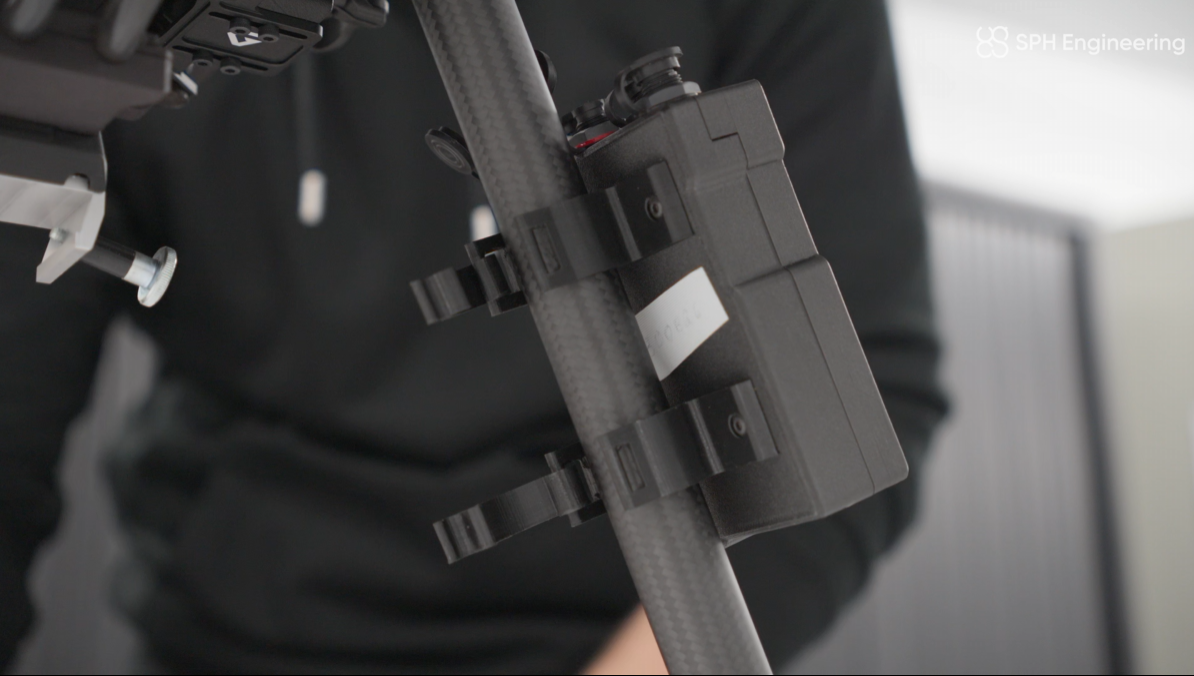
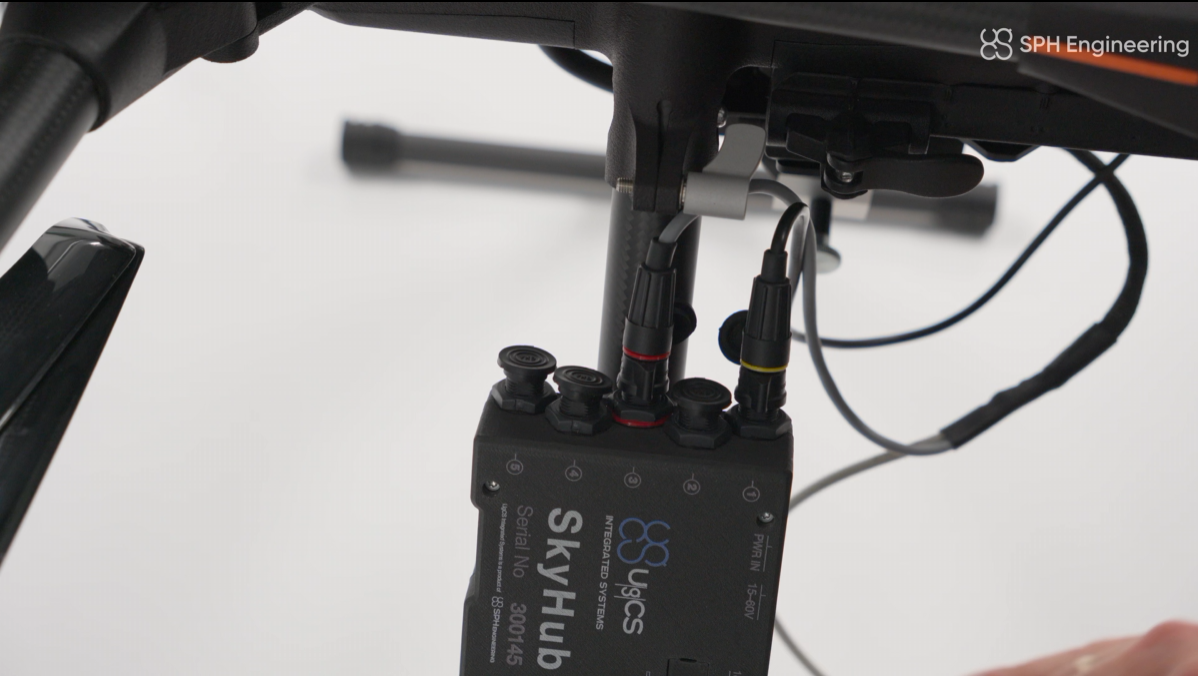
- Plug in the drone link cable (Red) to the third connector (Red) on the SkyHub.
- Plug the power cable into the first power port on SkyHub.
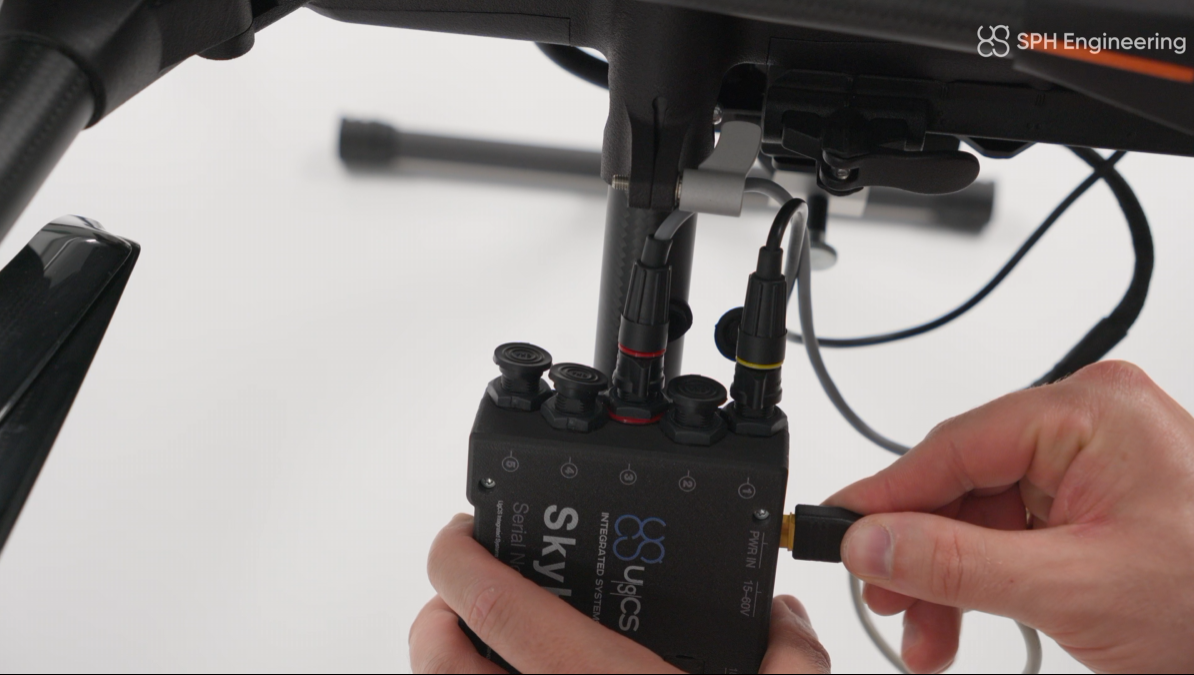
- Physical assembly of the SkyHub is complete. Check that all the connectors are secured tightly, with no loose movements.
Altimeter installation on the drone and connection to the SkyHub
To install the altimeter sensor on the IF800 Tomcat, use the mountings provided with the sensor.
Caution
At this point, the mounting bracket should already be installed on the drone.
Tip
For your convenience, we have a library with 3D models you can download and print yourself in case the default ones are broken or missing: 3D Part Library
- Slide the altimeter vertically on the previously attached bracket.
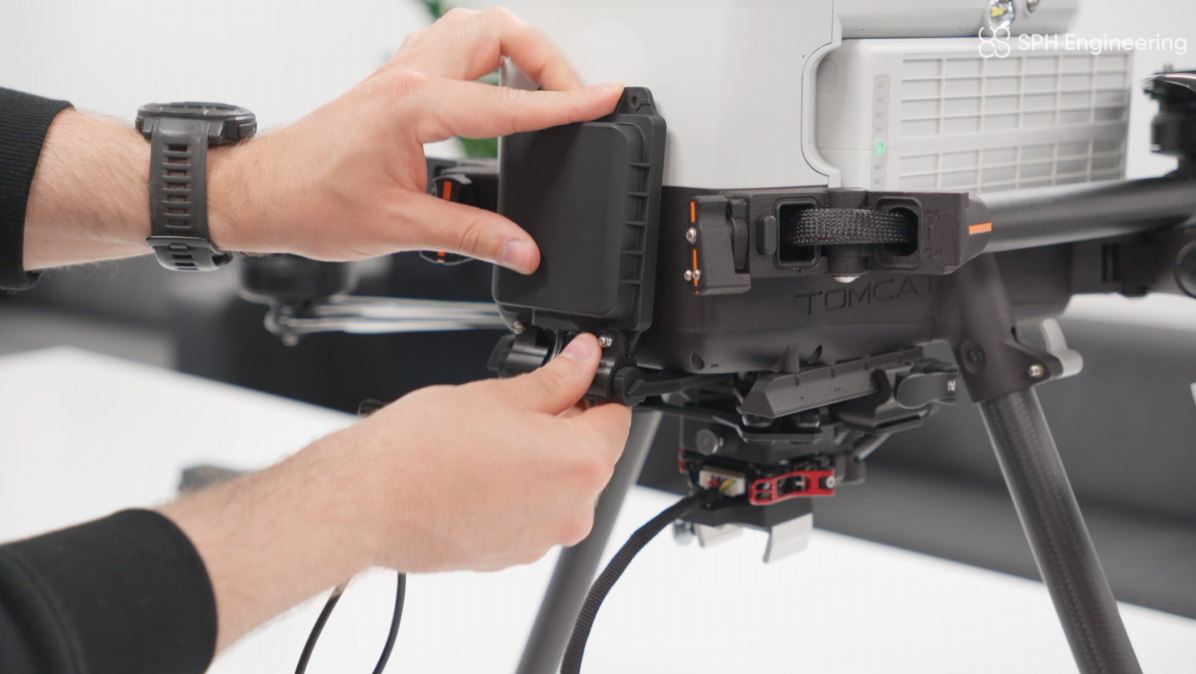
- Adjust the altimeter position by rotating it downwards or upwards.
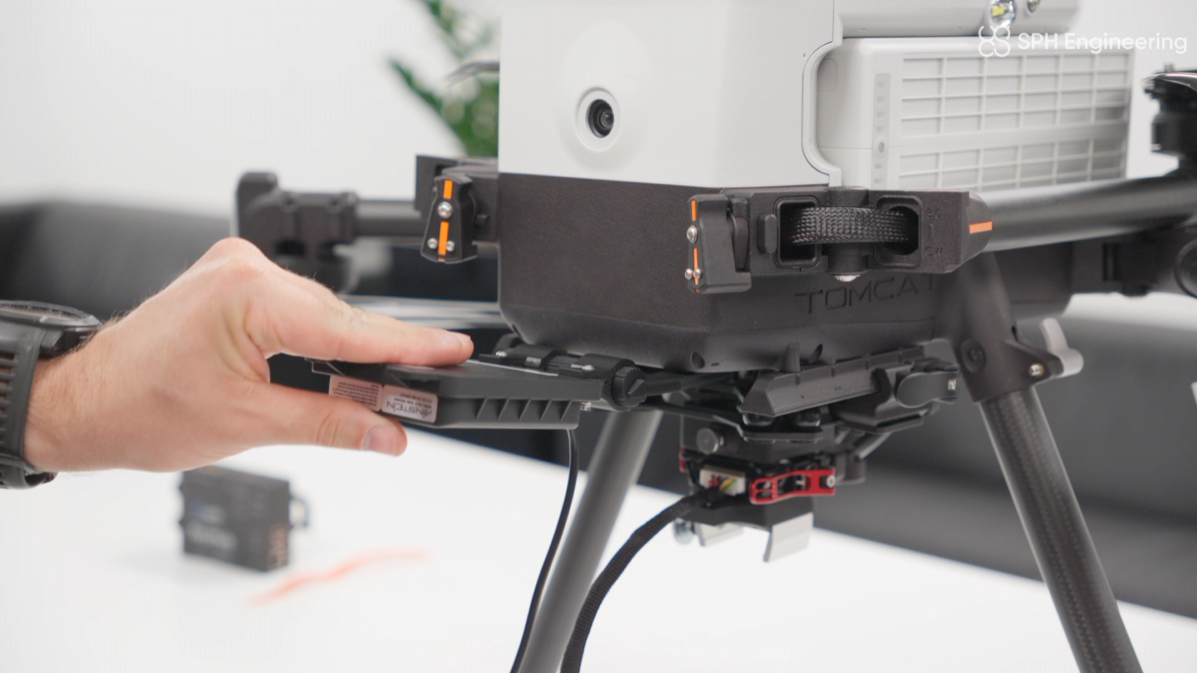
Note
If you wish to detach the sensor, simply perform the same action in reverse. Place the altimeter in the vertical position and slide it up from the gimbal.
- Connect the cable to Connector 1 (yellow) on the SkyHub.
- Setup is complete. You can now proceed with the widget configuration.
Altimeter / Autopilot configuration within the CPM software
Before proceeding further, power on both the drone and the remote controller. Then, make sure that your computer and the controller are connected to the same network. This is required to establish the drone link connection between CPM on your computer and SkyHub on the drone.
Note
SkyHub will take a little more time to fully boot up. You can check whether it is ready by the indicator within CPM. As soon as the SkyHub indicator becomes green, you can proceed with the configuration.
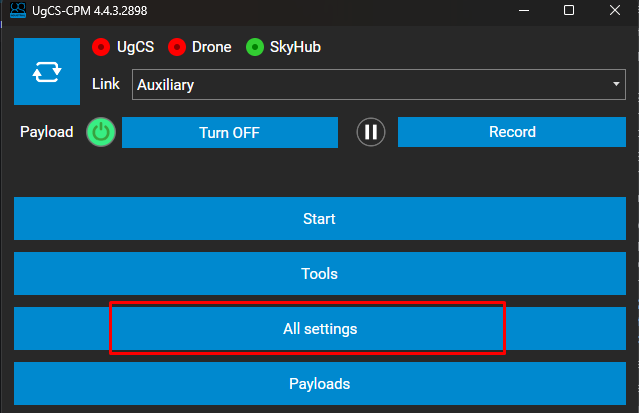
Enabling the autopilot
- Press the “All settings” button.
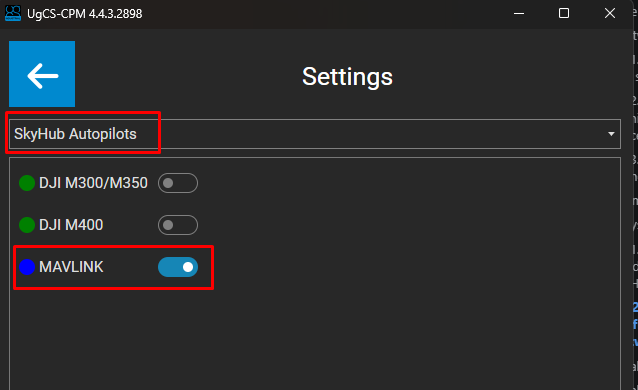
- From the drop-down list, select the “SkyHub Autopilots” section.
- Enable MAVLINK (note that only one autopilot can be enabled at a time). Press Save and perform a system restart.
Autopilot configuration is complete. After the system restart, you will notice that the drone link icon should become green.
Enabling the altimeter
When both drone link and SkyHub connections are established, you can proceed with the altimeter widget configuration.
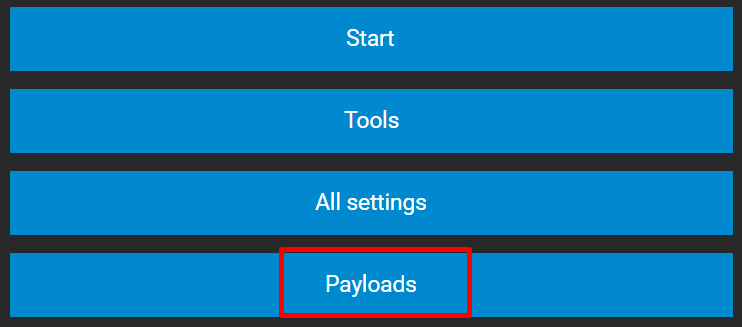
- Click on the Payloads section
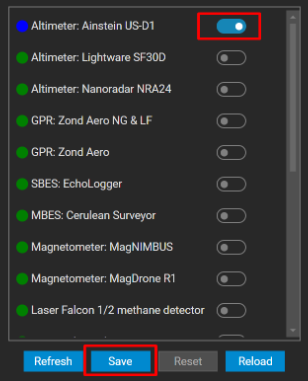
- From the payload list, search for your altimeter model (in our example, it is US-D1), enable it, and press the Save button. Perform a system restart.
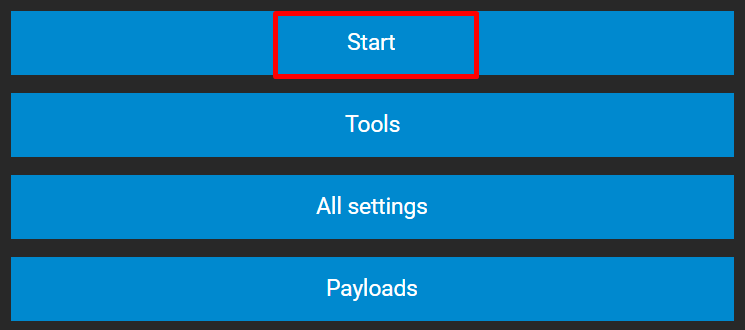
- After the restart is complete, press the Start button.
- From the drop-down list, select the altimeter model you enabled previously and press the “plus” icon
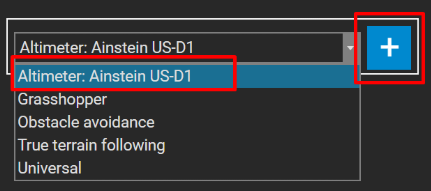
Widget configuration is complete. If everything was set up correctly, you should see the initial readings from the sensor.
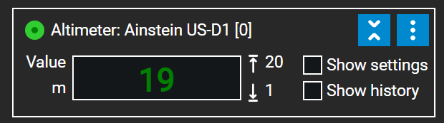
VSM configuration
- First, navigate to the VSM configuration file.
Microsoft Windows:
C:\Program Files (x86)\UgCS\bin\vsm-mavlink.conf
GNU/Linux:
/etc/opt/ugcs/vsm-mavlink.conf
Apple OS X:
/Users/[user name]/Library/Application Support/UGCS/configuration/vsm-mavlink.conf
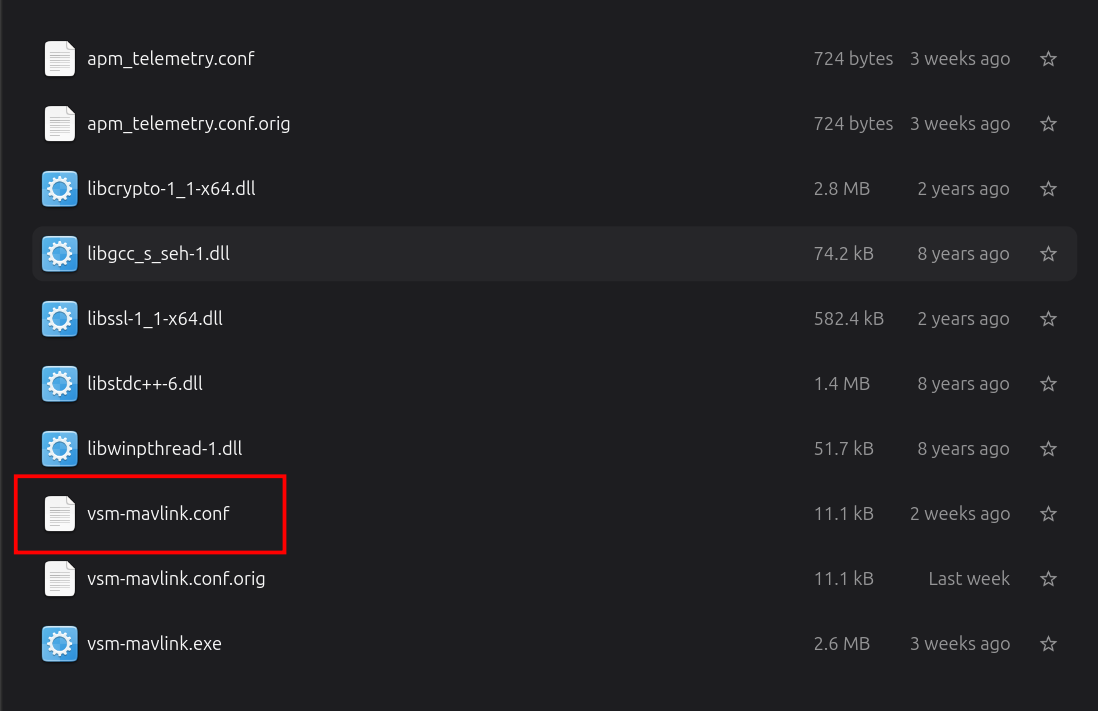
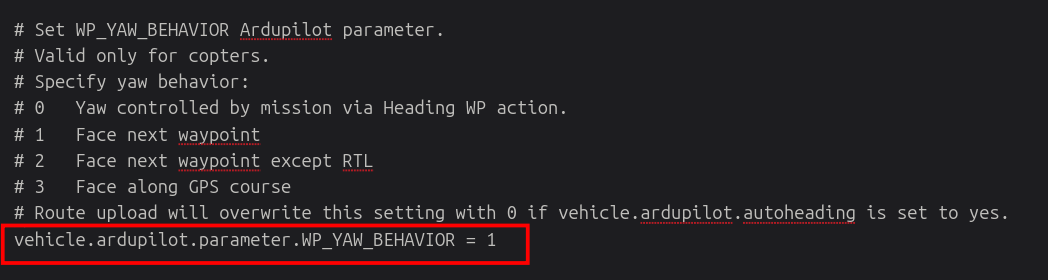
- Open the configuration file with any text editor and uncomment the line: vehicle.ardupilot.parameter.WP_YAW_BEHAVIOR = 1
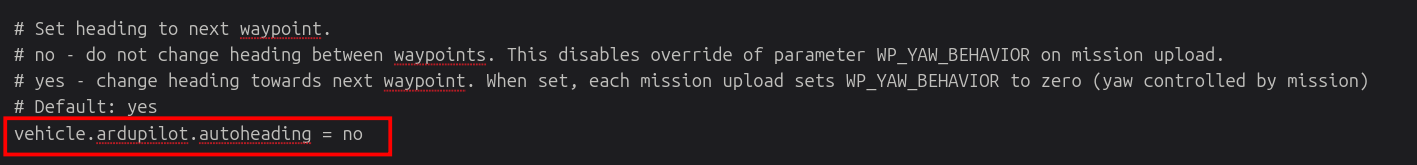
- Change the value of vehicle.ardupilot.autoheading to no
- Save the changes.
VSM configuration is complete.